

A research team comprising Emery Baroki Munphano, Alain Kammogne Soup Tewa, and Blampain Eloi Jean Jacques has introduced an advanced control strategy for automotive anti-lock braking systems, combining fractional-order calculus with a super-twisting sliding mode algorithm. Detailed in a study published in the journal Discover Vehicles, the investigation focuses on resolving the persistent trade-off between rapid wheel slip regulation and harmful control chattering during severe braking maneuvers. By establishing an adaptive fractional-order architecture, the authors demonstrate through extensive numerical simulations that their proposed controller significantly shortens stopping distances, maintains closed-loop stability, and effectively damps high-frequency oscillations across diverse road surfaces ranging from dry asphalt to packed snow and smooth ice.
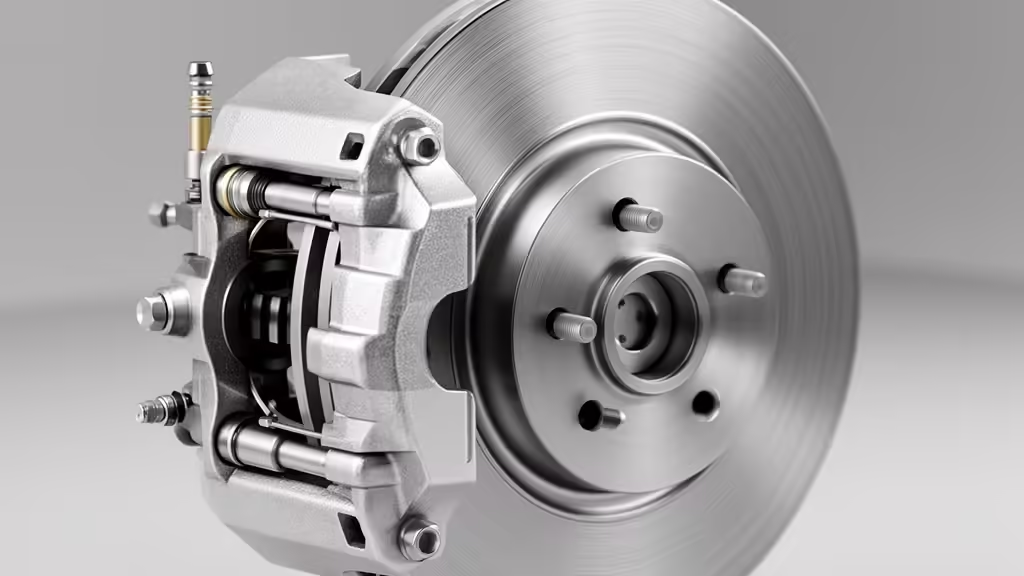
Anti-lock braking systems represent a vital active safety technology designed to prevent complete wheel lock-up during hard deceleration, thereby preserving vehicle steerability and directional stability. The core functional objective of an anti-lock braking system is to maintain the wheel slip ratio, defined as the normalized relative difference between the vehicle’s forward linear velocity and the rotational speed of the wheel, within a narrow optimal band typically situated between 10% and 20%. Operating within this targeted range maximizes the longitudinal friction coefficient generated at the tire-road interface. However, maintaining this slip ratio presents substantial control engineering challenges because the underlying tire-road friction dynamics are highly nonlinear, time-varying, and subject to dramatic external disturbances and sudden transitions between different surface adhesion levels.
Conventional control approaches historically deployed in automotive braking, including classical proportional-integral-derivative architectures and bang-bang regulators, frequently exhibit performance degradation or instability when confronted with abrupt variations in road grip and vehicle loading. While standard sliding mode control has emerged as a robust alternative capable of handling matched parametric uncertainties, it inherently suffers from chattering. This phenomenon involves high-frequency switching oscillations that excite unmodeled mechanical dynamics, cause severe premature wear on braking actuators, and reduce passenger ride comfort. Although higher-order sliding mode algorithms such as the super-twisting method act on the sliding variable’s time derivatives to smooth out control signals, conventional formulations rely on integer-order vehicle models that struggle to capture non-local memory effects and complex viscoelastic behaviors inherent to tire deformation.
To overcome these limitations, the authors integrated fractional-order calculus into both the vehicle dynamic formulation and the sliding mode control law, adopting the Caputo fractional derivative definition. The mathematical formulation utilizes non-integer differentiation orders bounded strictly between zero and one. The choice of the Caputo definition is specifically motivated by fundamental physical considerations: unlike the Riemann-Liouville alternative, the Caputo operator requires initial conditions expressed through standard integer-order derivatives, such as initial vehicle longitudinal speed and wheel angular velocity, which are directly measurable by conventional onboard automotive sensors. Furthermore, the Caputo derivative of a constant is identically zero, ensuring that steady-state equilibrium conditions reflect an absence of dynamic change, which significantly simplifies Lyapunov-based stability analyses.
The physical system was modeled as a quarter-vehicle anti-lock braking assembly incorporating longitudinal dynamics, rotational wheel inertia, actuator braking torque, and nonlinear contact forces governed by Coulomb’s law. The relationship between longitudinal adhesion and wheel slip was modeled using the empirical Burckhardt tire friction formulation, which accounts for the characteristic friction peak and post-peak drop-off under distinct surface environments. Applying Newton’s second law alongside the Caputo derivative operator yielded coupled fractional-order differential equations that govern the deceleration of the vehicle mass and the angular deceleration of the rolling wheel. In the simulation framework, the vehicle’s initial velocity was specified at 20 meters per second, corresponding to an initial wheel angular speed of 64.5 radians per second given the effective rolling radius.
The controller architecture utilizes a direct slip control topology configured for each wheel assembly, tracking the error between the dynamically observed wheel slip and the targeted set point. An adaptive fractional-order sliding manifold was synthesized using a combination of fractional integration and fractional differentiation of the slip tracking error, scaled by a design parameter denoted as K1. By taking the time derivative of the sliding surface and separating the continuous equivalent control from the discontinuous robust switching term, the control law compensates for nominal vehicle dynamics while actively rejecting external disturbances. The continuous equivalent component maintains the system trajectory on the sliding surface during nominal operation, whereas the discontinuous component counteracts parameter perturbations and road uncertainties.
To eliminate the need for prior knowledge regarding disturbance upper bounds, the control law incorporates an adaptive gain majorization mechanism based on barrier-type principles. The disturbance term is decomposed into a square-root growth component and a Lipschitz-continuous perturbation, each bounded by unknown positive constants. The controller dynamically updates two adaptive gain parameters, denoted as R and Q, which are systematically tuned using positive constants to guarantee that the control gains dominate unknown perturbations at all positive operating times. Crucially, the gain adaptation law transitions from a linear growth phase to a constant holding value after a specified initial time horizon of 0.5 seconds, entirely preventing the free-wheeling phenomenon characterized by unbounded gain growth and excessive actuator saturation.
The mathematical rigor of the proposed scheme was substantiated through a Lyapunov stability proof adapted to fractional-order systems using a state-dependent quadratic candidate function. By introducing an explicit diffeomorphism that maps the system state into transformed coordinates, the researchers established a linear matrix representation of the closed-loop error dynamics. Utilizing the fractional Leibniz product rule and bounding infinite memory summation terms through Rayleigh inequalities, the analytical derivation demonstrated that the fractional derivative of the Lyapunov function satisfies a finite-time convergence criterion. Settling time upper bounds were explicitly derived, confirming that both the sliding variable and the slip tracking error converge to zero in finite time under nominal stability parameters satisfying positive-definiteness constraints.
Numerical verification was conducted within a MATLAB/Simulink R2024a simulation environment, implementing the Oustaloup recursive filter approximation method to represent fractional-order operators as integer-order rational transfer functions across the frequency domain. Five distinct road conditions were evaluated: dry asphalt, dry concrete, wet road, snow, and ice. Initial simulation parameters included a fractional differentiation order of 0.99, an adaptation slope of 1000, initial gain of 1000, sliding manifold parameter K1 of 80, and an actuator torque limit fixed at 2000 Newton-meters. The reference slip ratio was set to a constant optimal value of 0.15 to evaluate tracking accuracy, deceleration consistency, and actuator energy modulation under identical disturbance profiles.
The simulation results confirmed that vehicle deceleration closely followed theoretical friction limits across all tested surfaces. On high-friction dry asphalt, the vehicle achieved a near-optimal deceleration rate of approximately 8.5 meters per second squared, bringing the vehicle to a full stop within 2.3 seconds. Performance on dry concrete was nearly identical, exhibiting an increase in total stopping time of only 0.1 seconds. As available adhesion decreased, deceleration dropped to approximately 6.2 meters per second squared on wet asphalt, requiring 2.8 seconds to stop. On snow, maximum deceleration fell to 3.1 meters per second squared, while on ice, deceleration dropped to 1.8 meters per second squared, preventing the vehicle from achieving a complete stop within the simulated temporal window.
Comparative analyses against integer-order super-twisting sliding mode control and adaptive proportional-integral-derivative benchmarks highlighted substantial improvements in braking efficiency and tracking precision. On dry asphalt, the fractional-order controller achieved a settling time of 0.15 seconds with a steady-state slip error below 0.005 and overshoot under 2%, reducing the total stopping distance by 2.8 meters compared to the integer-order super-twisting controller. On icy roads, the proposed controller achieved an absolute root mean squared error of 0.0285, representing a 36% error reduction relative to the integer-order super-twisting benchmark and a 54% reduction relative to the adaptive PID regulator. Furthermore, the controller reduced stopping distance on ice by 13.8 meters compared to integer-order sliding mode control, providing a decisive safety margin under extreme adhesion loss.
Detailed spectral and sensitivity evaluations revealed key operational insights into the controller’s robustness and physical limitations. Frequency analysis showed that tracking error spectra on high-friction surfaces were concentrated above 50 Hertz, indicating successful chattering suppression, whereas low-adhesion surfaces exhibited low-frequency oscillations between 2 and 10 Hertz driven by nonlinear tire-road dynamics. Actuator analysis indicated smooth torque delivery near saturation for 75% to 85% of the braking cycle on dry asphalt, compared to rapid modulation between 40% and 60% on ice. Sensitivity sweeps confirmed that K1 set to 80 and a fractional order of 0.99 yielded optimal performance trade-offs, outperforming both integer-order derivatives and lower fractional values. The authors concluded that future research will focus on experimental embedded implementation and integrating friction-adaptive estimation mechanisms to further mitigate low-frequency oscillations on slippery surfaces.
Subject of Research: Fractional-order super-twisting sliding mode control for automotive anti-lock braking systems
Article Title: Flexible super twisting adaptive robust control for fractional antilock braking system
Article References: Munphano, E. B., Tewa, A. K. S., & Jacques, B. E. J. (2026). Flexible super twisting adaptive robust control for fractional antilock braking system. Discover Vehicles, 2(1), Article 18. https://doi.org/10.1007/s44465-026-00019-y
Image Credits: AI Generated
DOI: 10.1007/s44465-026-00019-y
Keywords: anti-lock braking systems, sliding mode control, super-twisting algorithm, fractional calculus, vehicle dynamics, stopping distance, wheel slip regulation, adaptive control, Flexible, super, twisting, adaptive
Source: bioengineer.org